Thank you to Andrea Kalmans and Jennifer Kaehms for hosting Heeyong Huh and Luis Sentis on America’s Angels and bringing Austin’s research and entrepreneurship communities into thoughtful conversation. Heeyong, our former PhD student and now founder and CEO of Suhwa, is developing wearable interfaces that translate subtle hand gestures and neuromuscular signals into digital actions. His work connects fundamental research with practical questions about how people interact with increasingly capable machines.
Reimagining Human-Robot Interaction: A Sony-UT Austin Collaboration
We are happy to share that we recently collaborated with Sony to design and test new interfaces for human-robot interaction. This project focuses on integrating dexterous robotic hands with custom haptic wearables to improve teleoperation and physical manipulation within robotic systems.
System Architecture and Focus
-
Design of multi-fingered dexterous robotic manipulators.
-
Design of of haptic feedback wearables for real-time sensory transmission.
-
Evaluation of tactile accuracy and latency during object manipulation tasks.
PI Luis Sentis at Fundació “la Caixa” in Madrid
The ARISTO Hand for Fine-Grained Manipulation
We are pleased to showcase the ARISTO (Anthropomorphic, Robotic, Integrated-Sensing, Tendon-Operated) Hand. Developed in collaboration with Sony Group Corporation. This research platform is engineered to address the complex requirements of manipulating small, thin, and fragile objects.
Visit the project website here: https://aristohand.github.io to read the full publication, view the mechanical architecture, and watch our task-level demonstrations.
Inaugural Freshman Space Robotics Course Final Projects
Huge kudos to HCRL postdoc Alex Ambrose and PhD student Susan McLain for designing and teaching the first freshman Space Robotics Course at UT Austin. Check out the video below to see the students’ final project: a flywheel-controlled camera designed for precision tracking. Fantastic work by everyone involved!
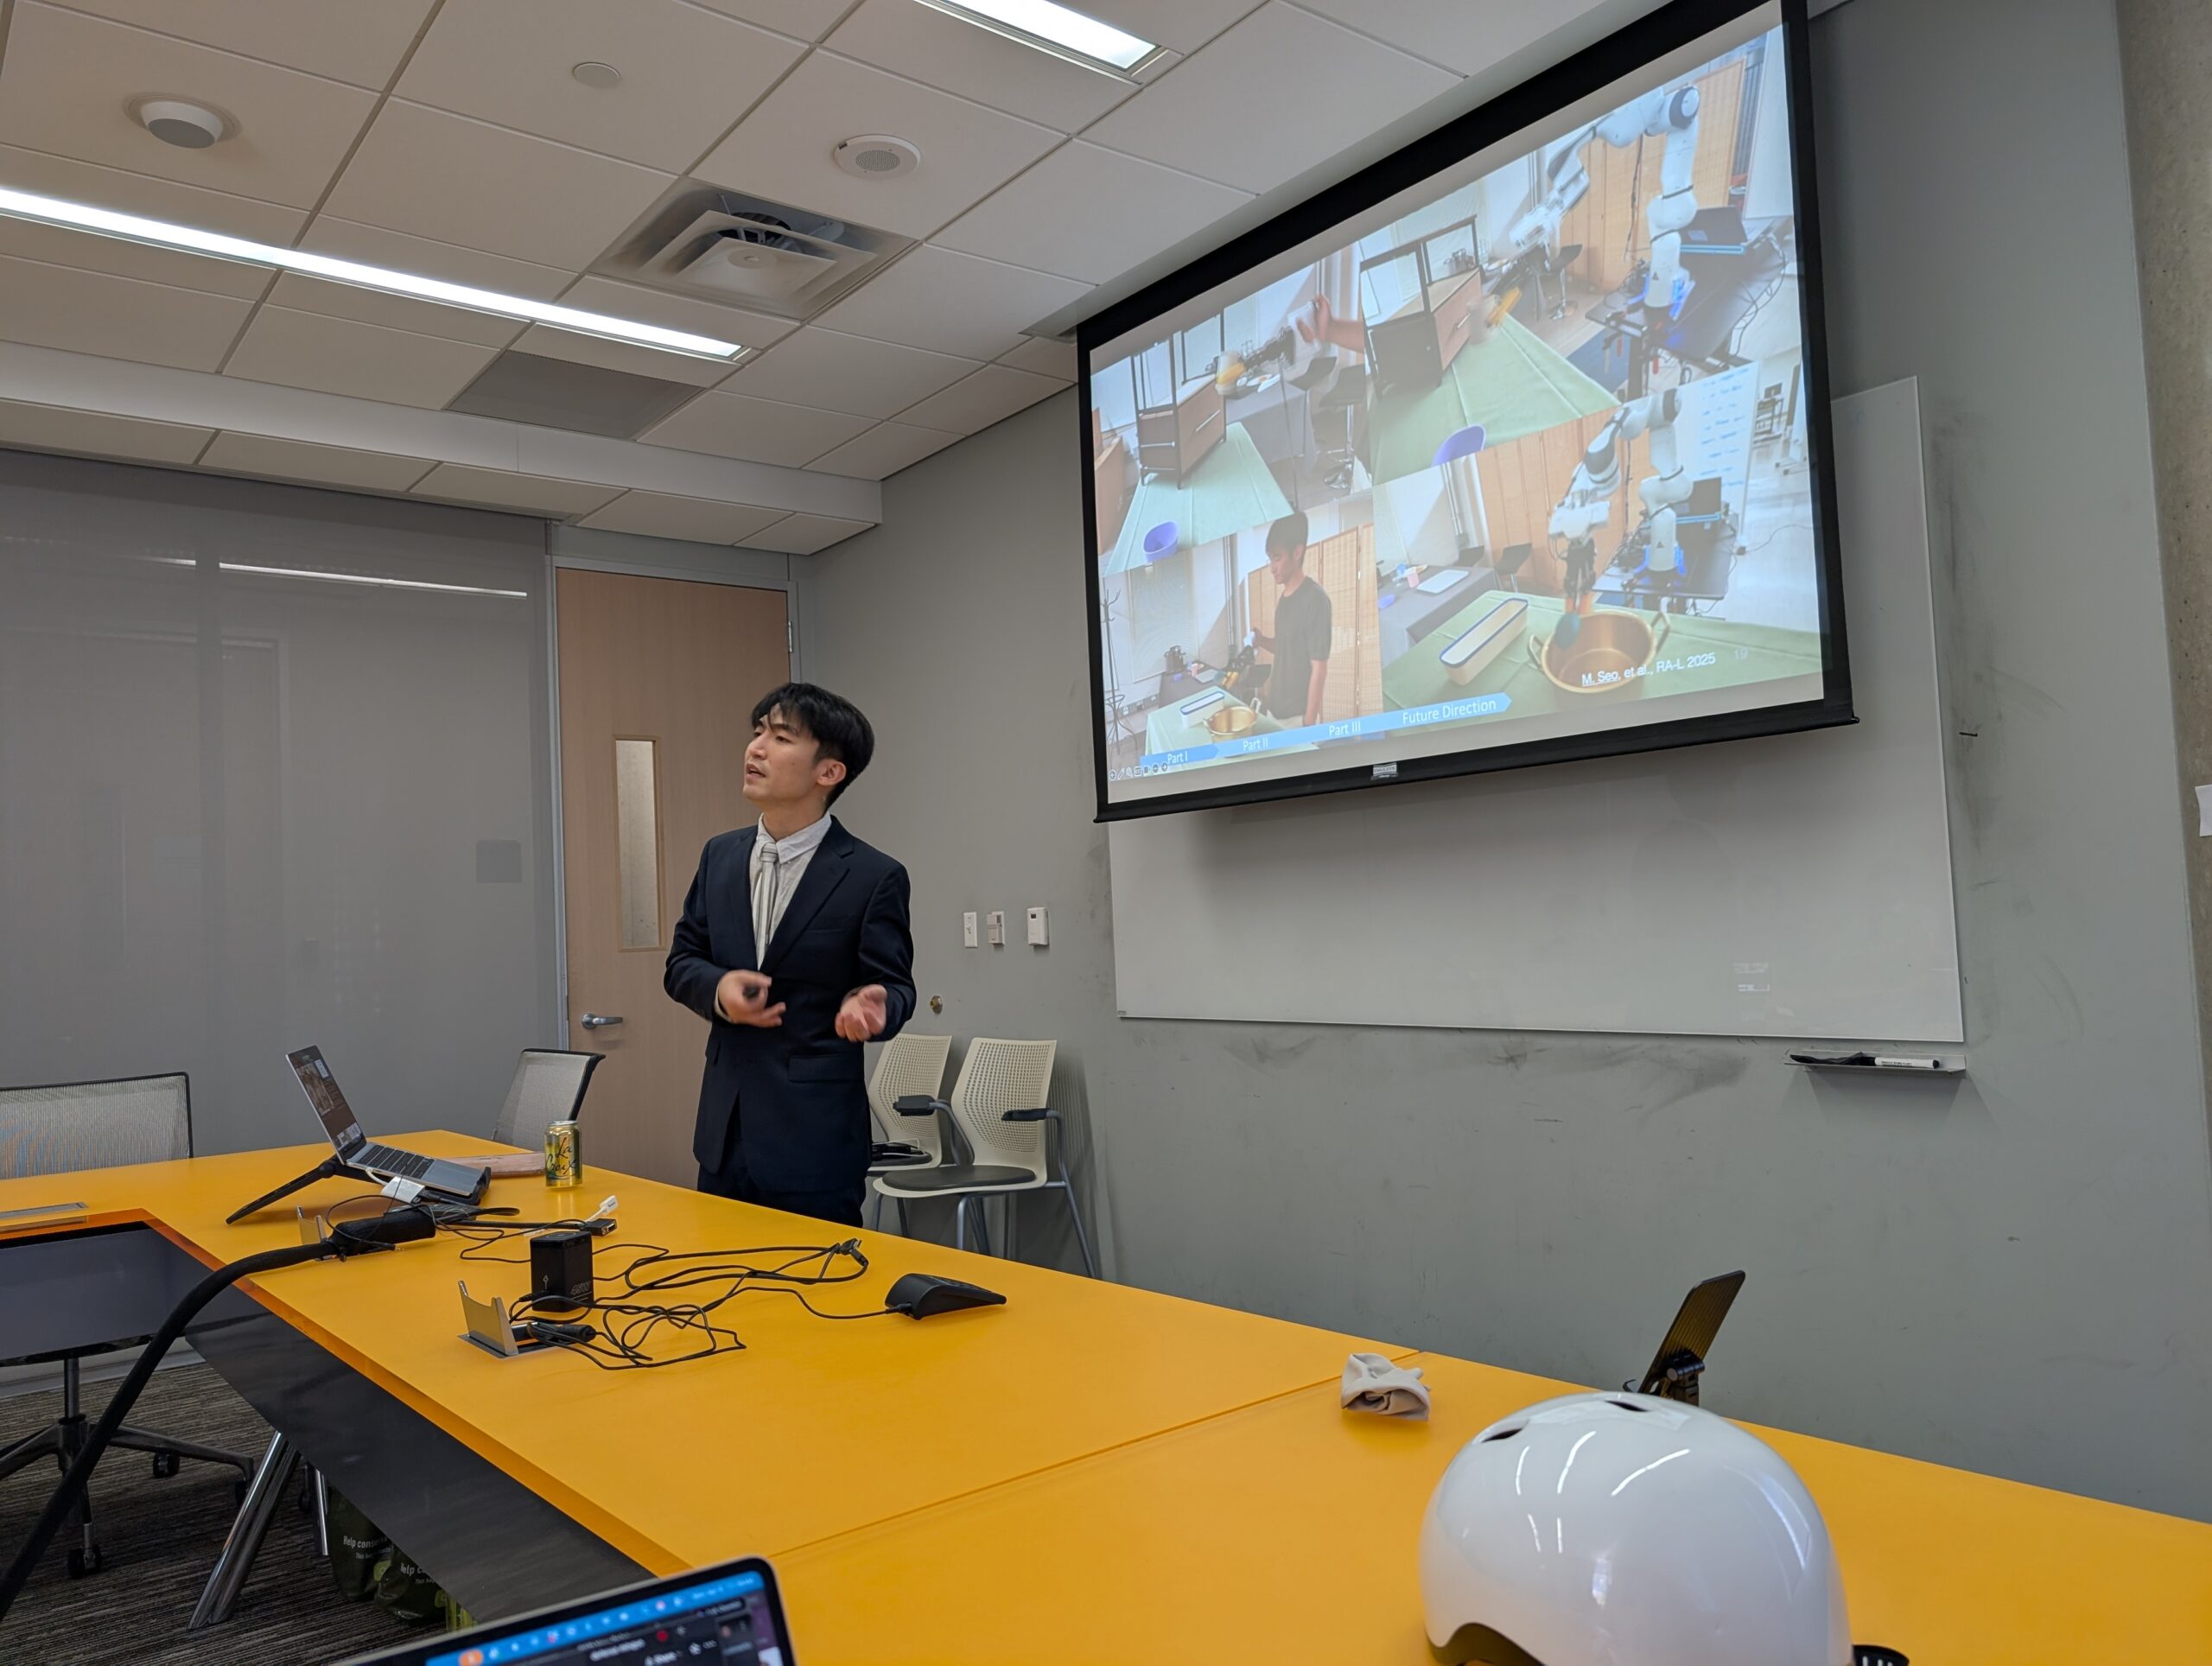
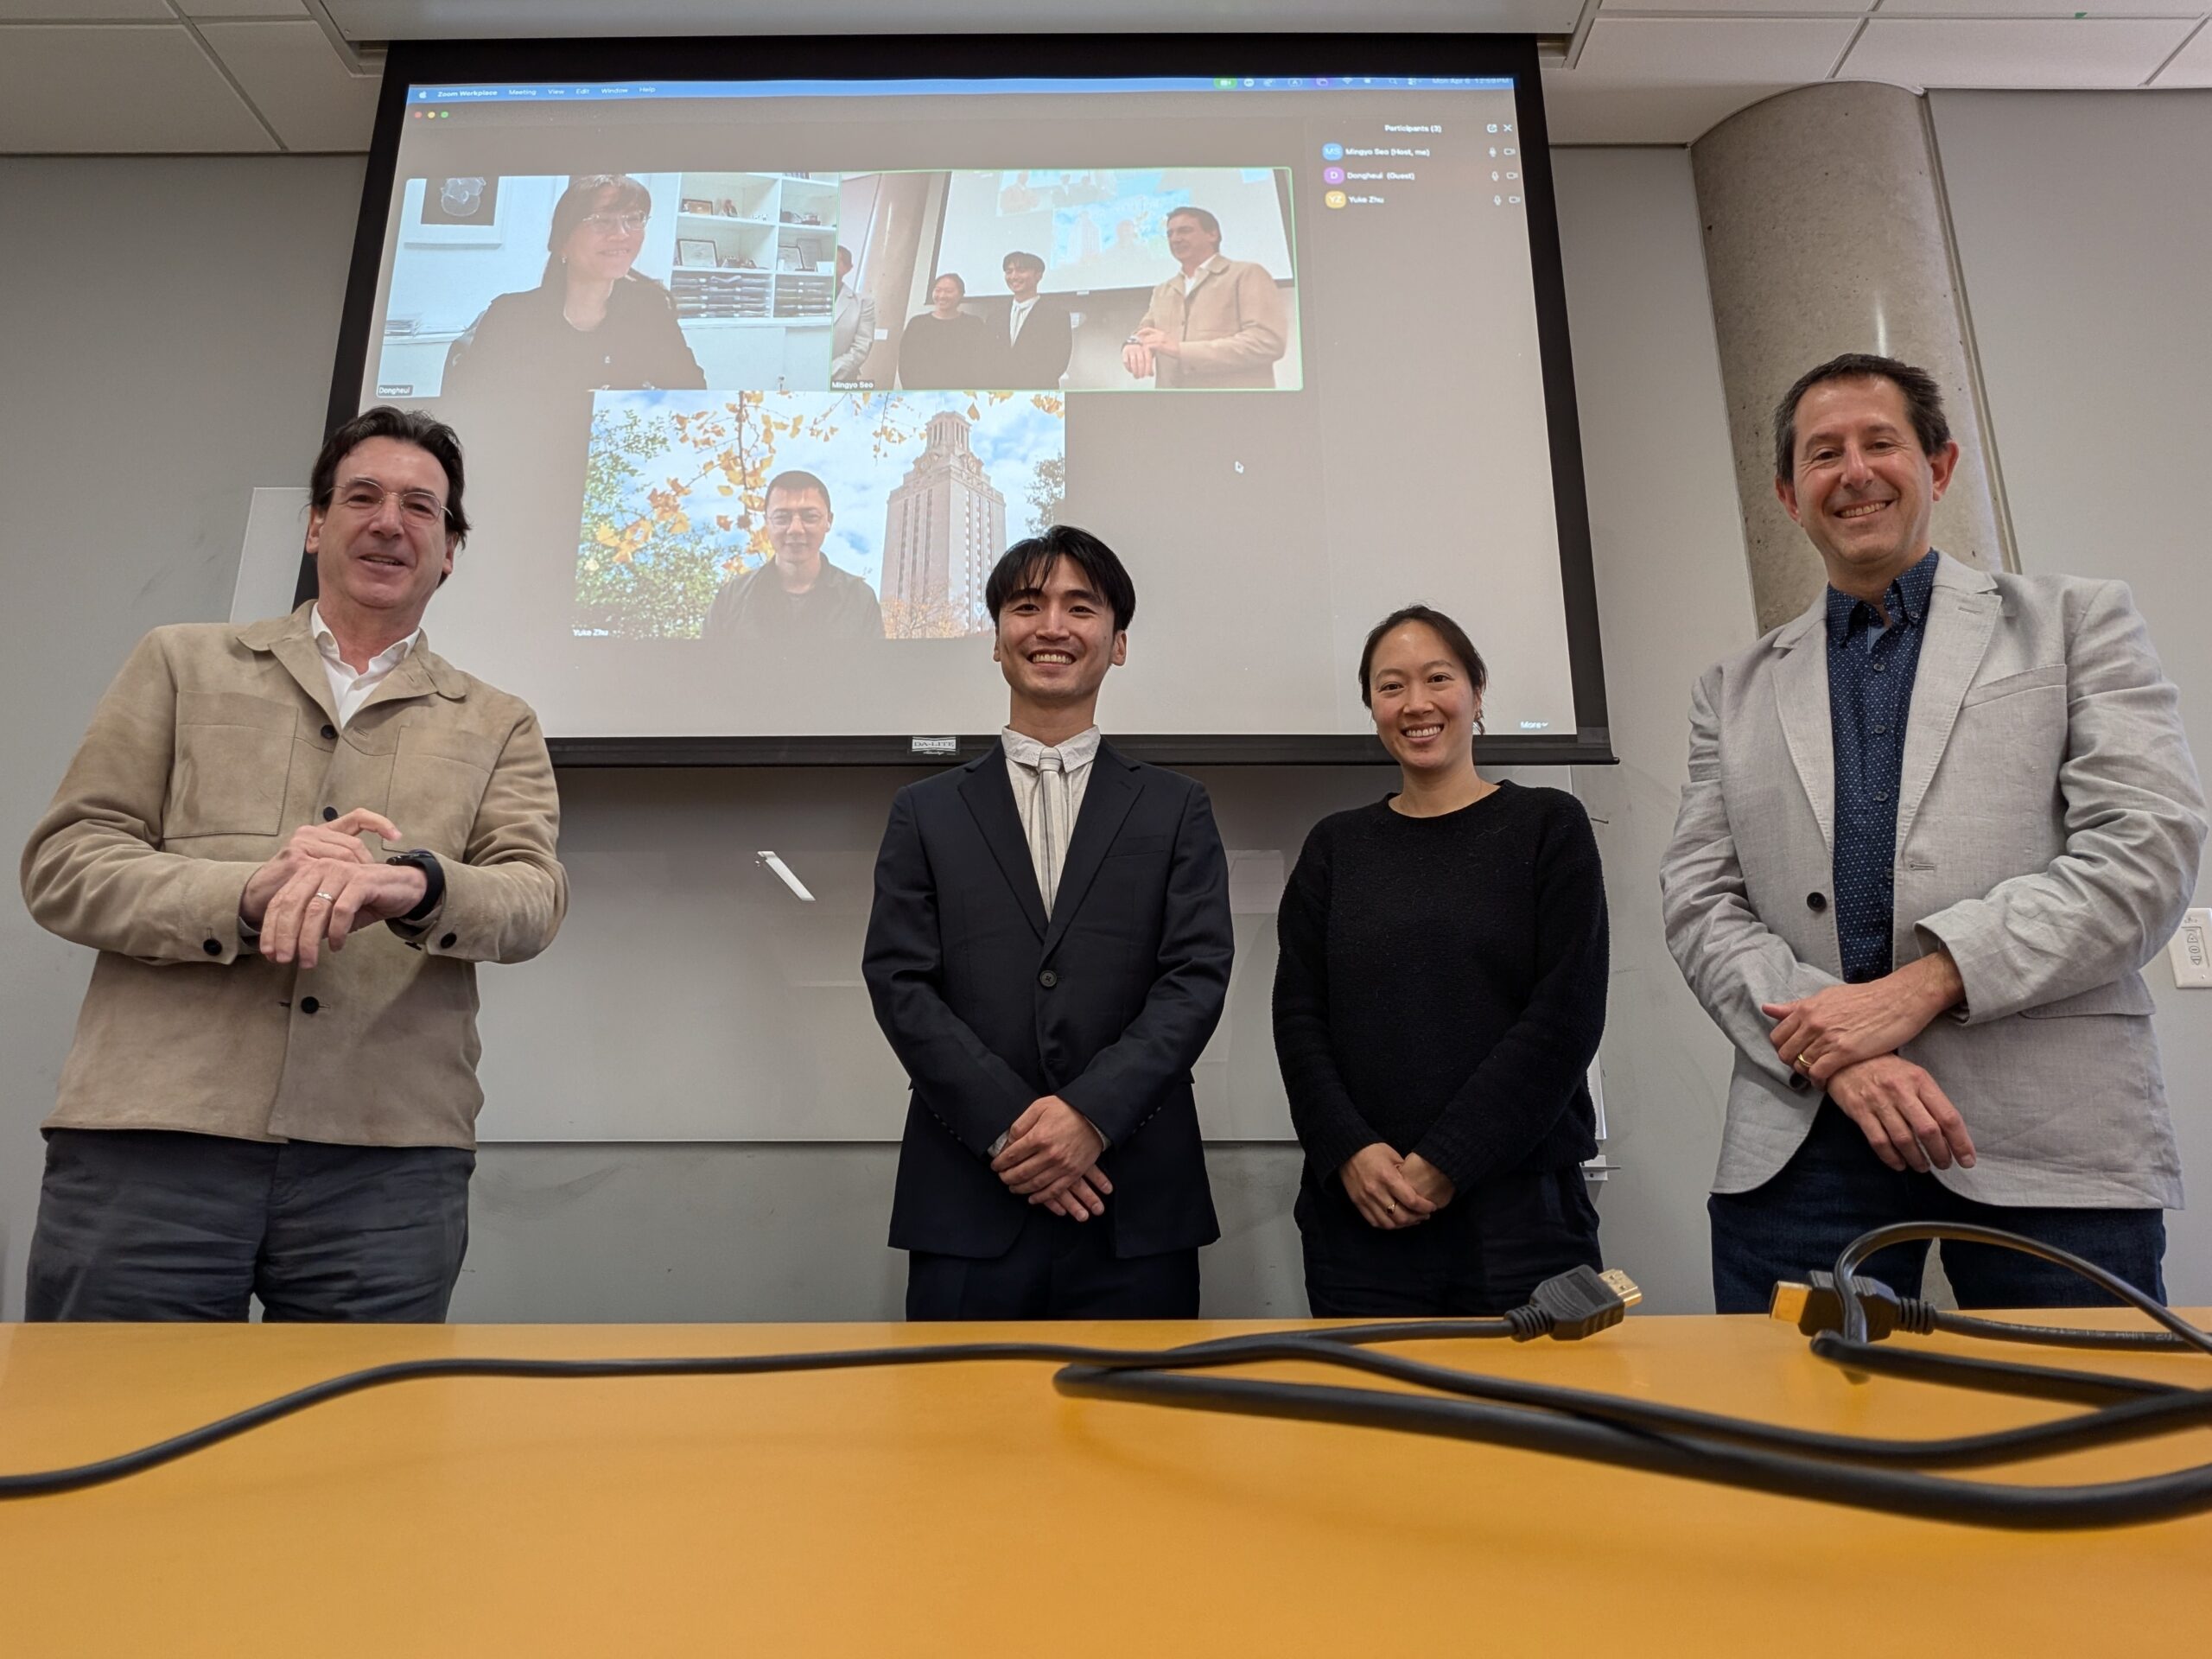
PhD Thesis Defense of Mingyo Seo
We are proud to congratulate Mingyo Seo on the successful defense of his doctoral thesis:
“Embodiment-Aware Skill Learning for Diverse Robots”
Mingyo’s research addresses a fundamental challenge in robotics: how to enable robots with different physical structures—varying shapes, sizes, and capabilities—to learn and perform skills effectively. His work introduces novel approaches to embodiment-aware learning, allowing robotic systems to adapt skills based on their unique physical configurations rather than relying on one-size-fits-all solutions.
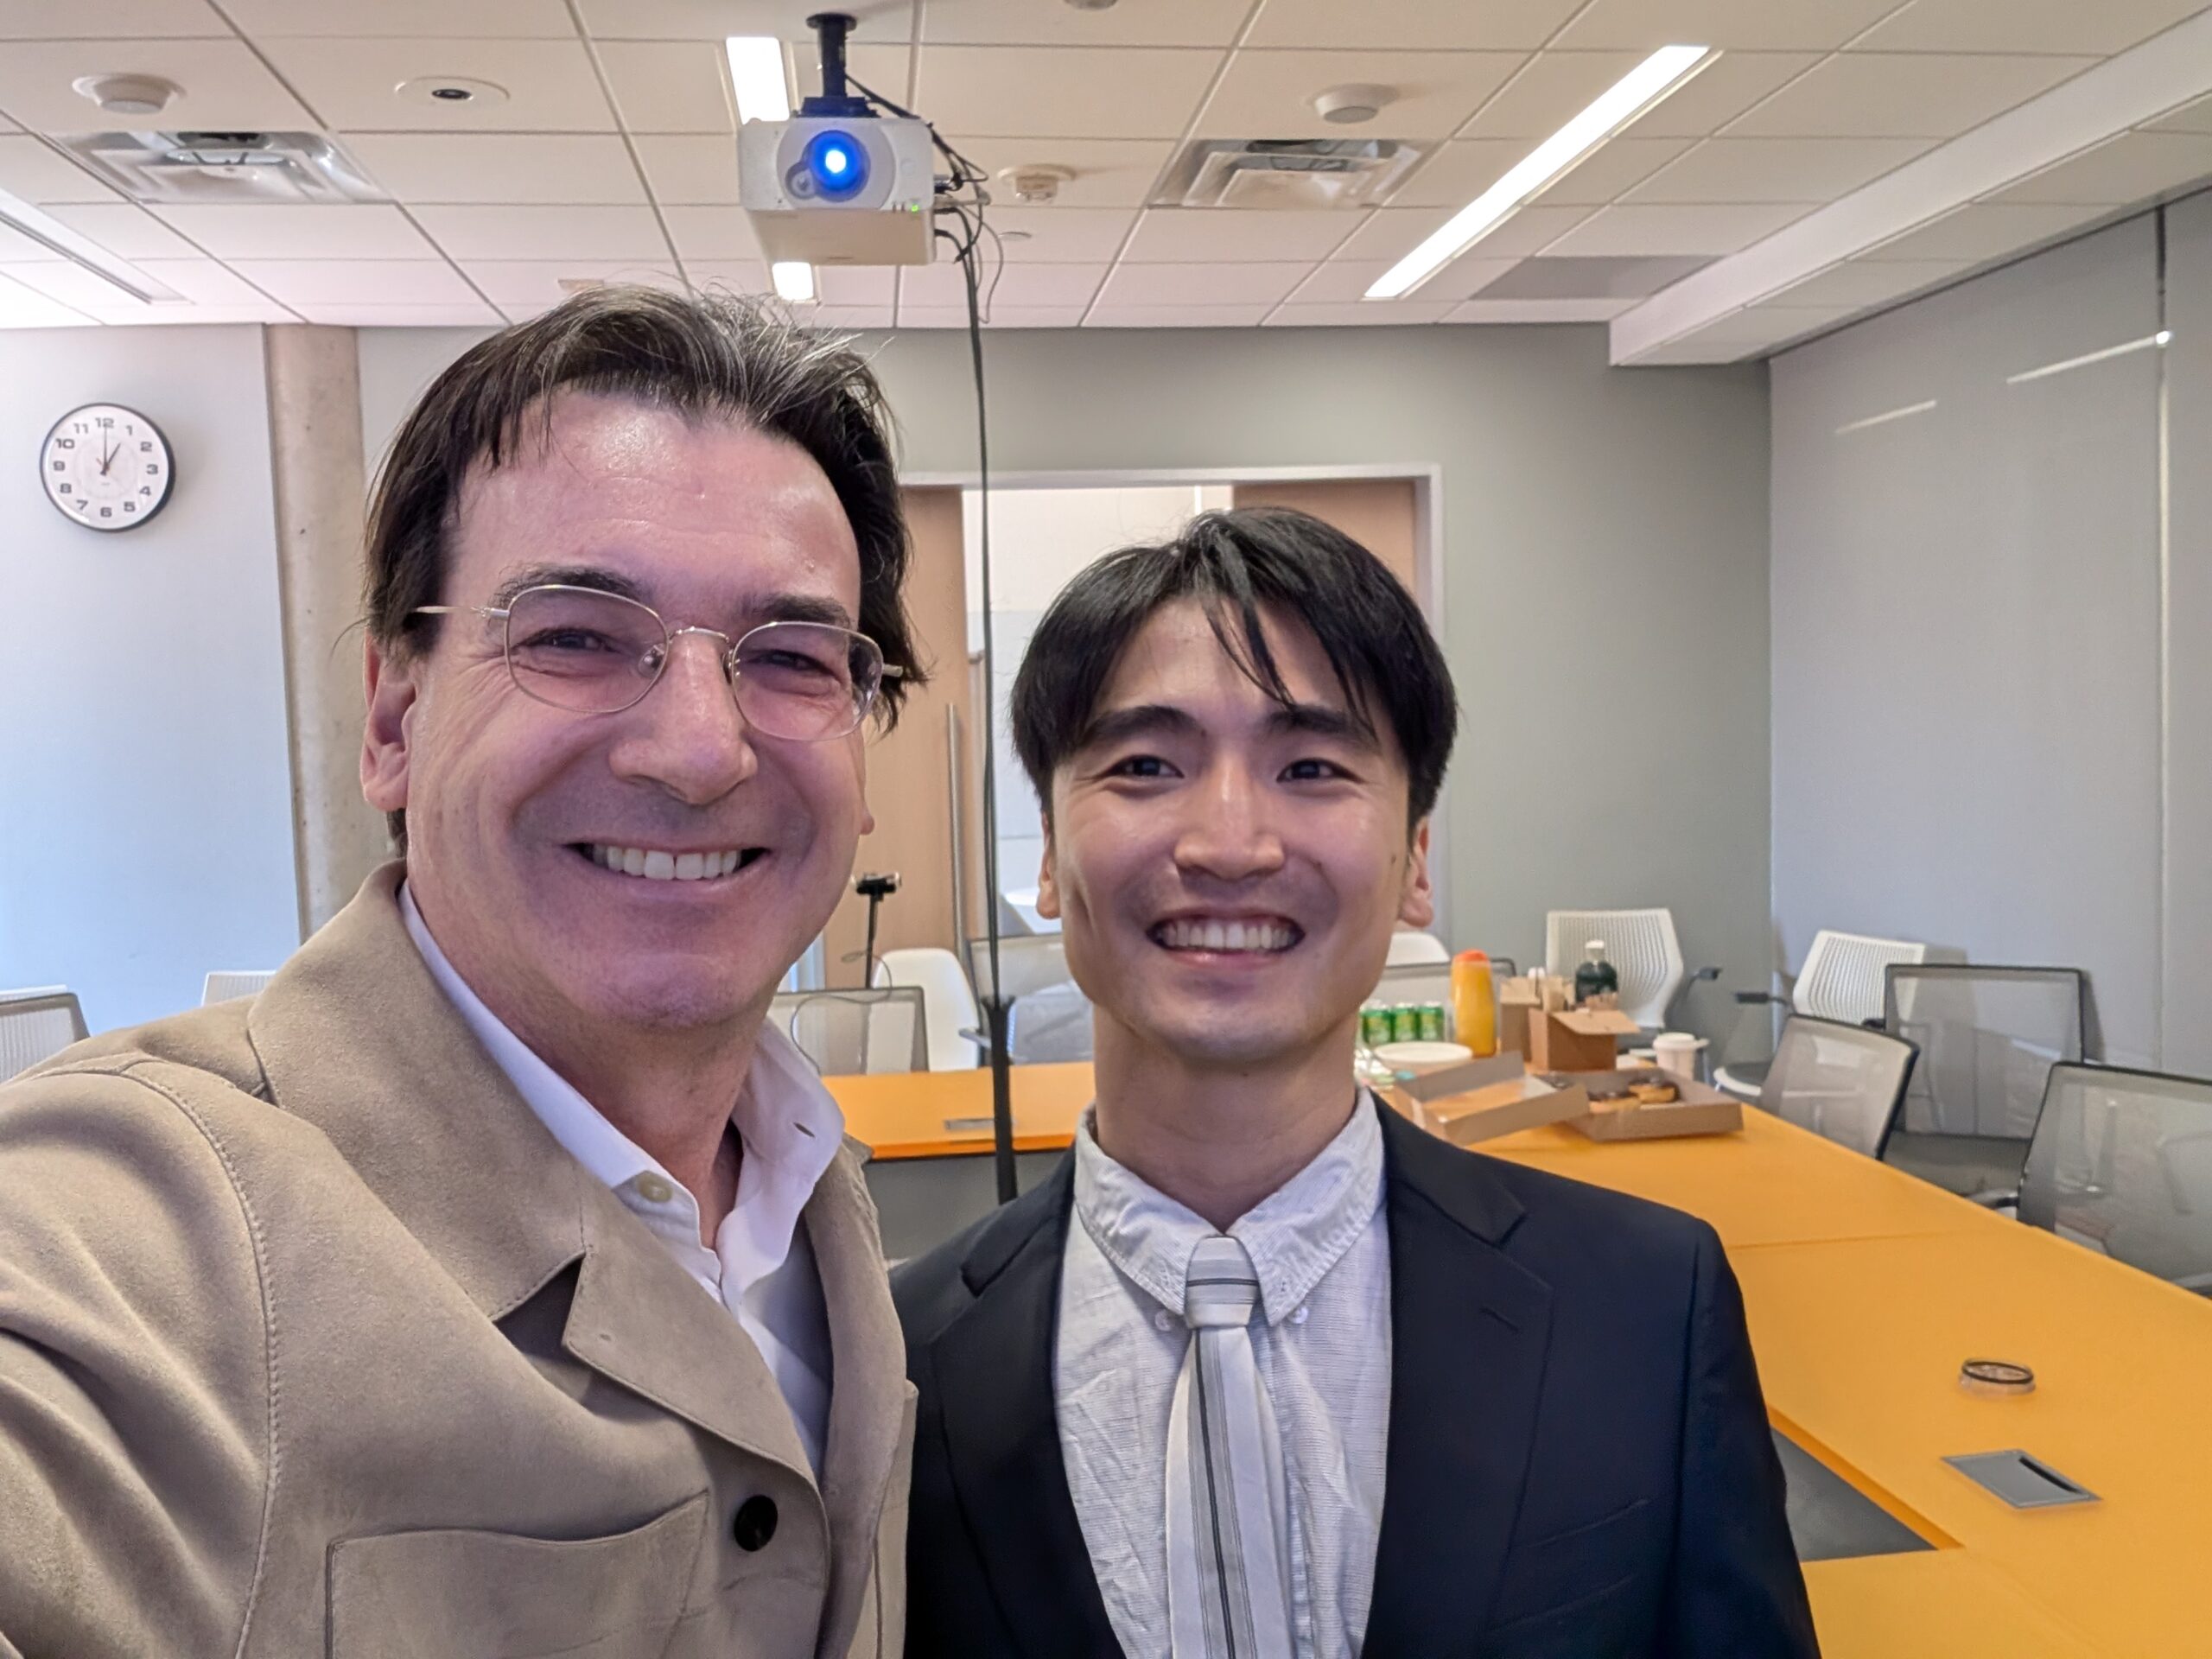
PhD Graduation Season Continues…
Carlos successfully defended his thesis, titled “Dynamic Whole-Body Planning for Humanoids in Confined Spaces: A Morphology-Aware Synthesis Approach”. His research significantly advances the state-of-the-art for humanoid robots navigating complex and unstructured environments. We are incredibly proud of Carlos’s hard work and dedication!
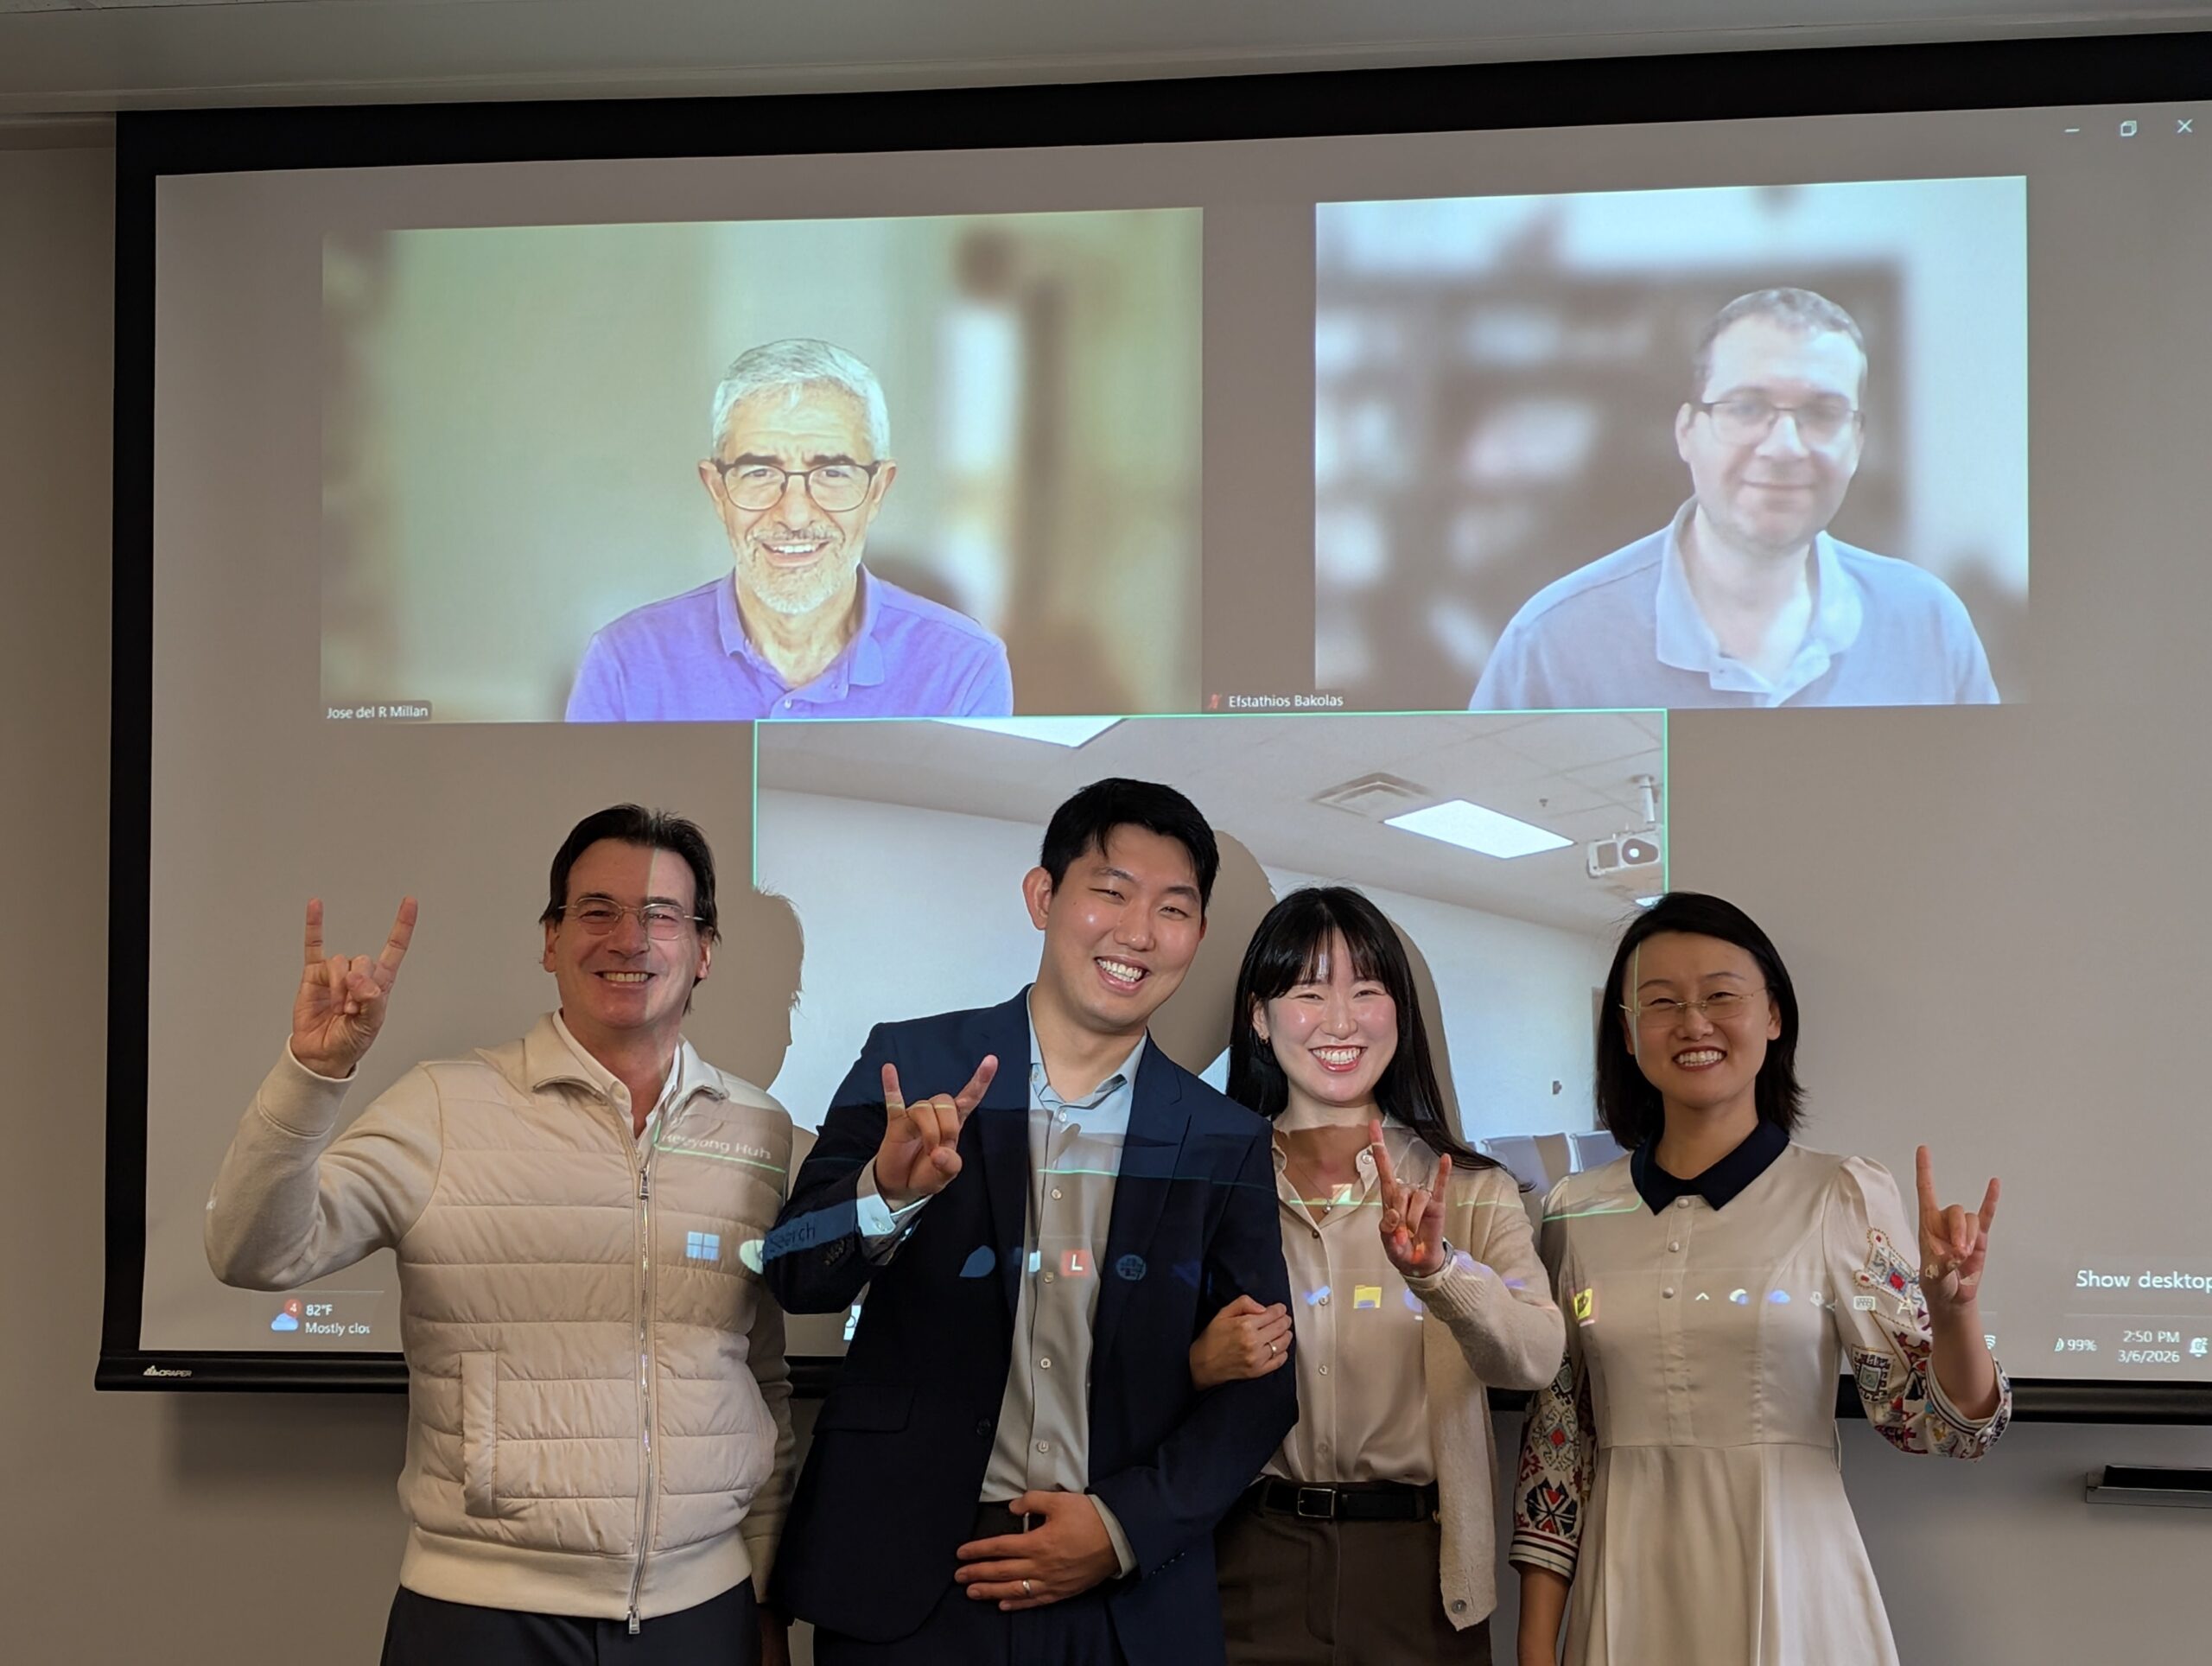
17th PhD Milestone: Congrats Dr. Heeyong Huh!

HCRL Featured in the New Microsoft Copilot Ad
From the Lab to the Global Stage
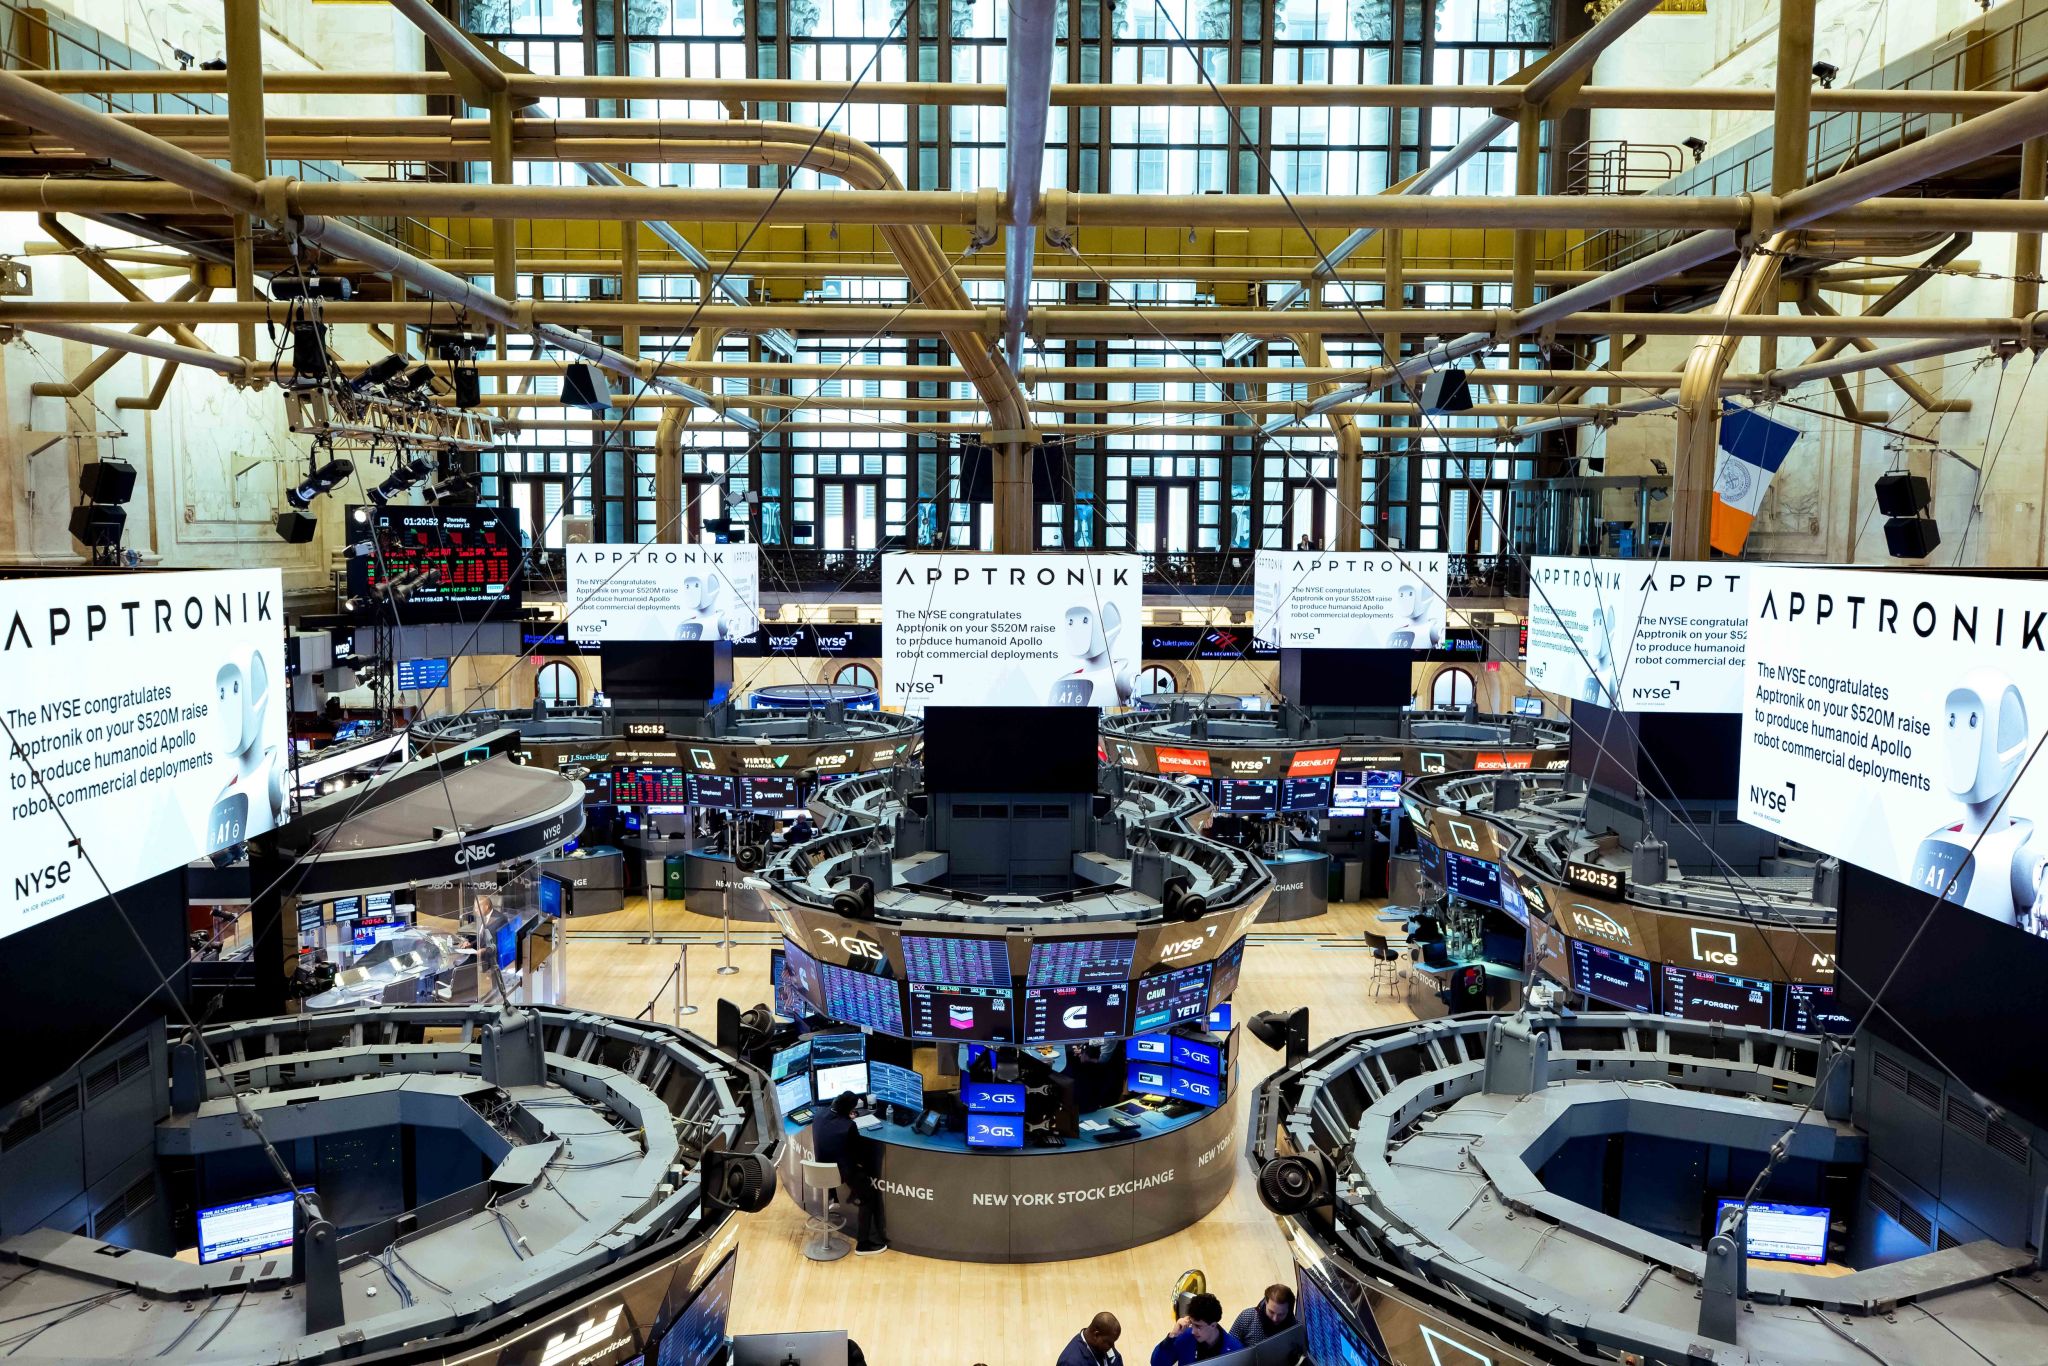
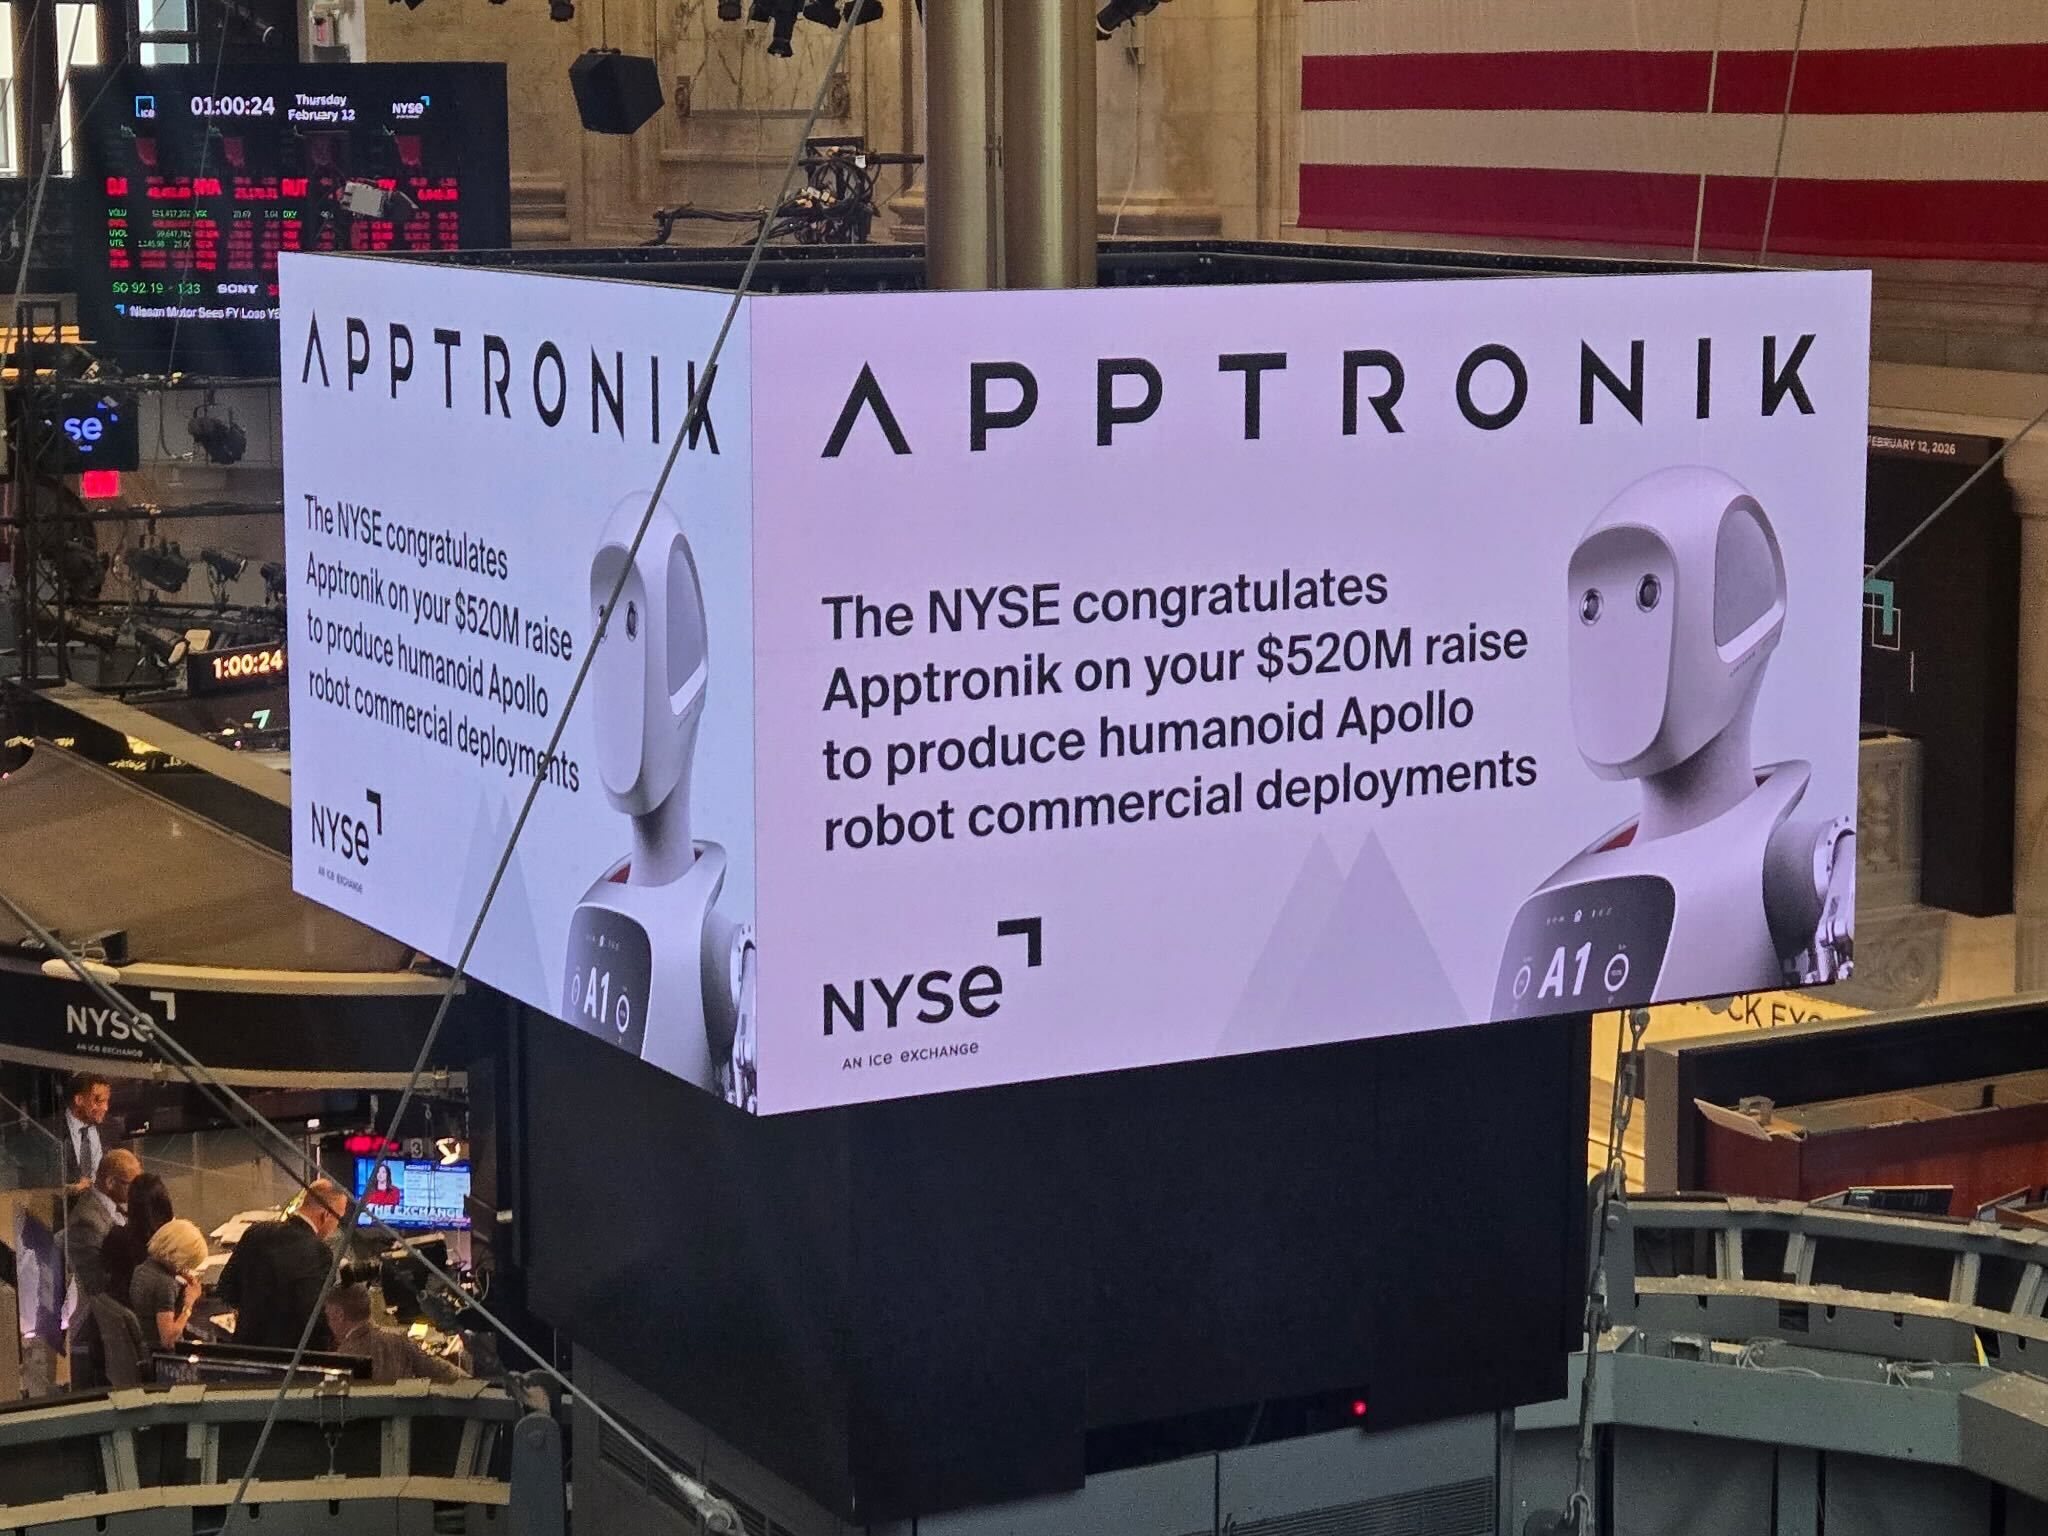
We are thrilled to celebrate Apptronik’s recent raise, announced at the New York Stock Exchange. Spanning off from our laboratory and co-founded with our lab’s former student, CTO Nick Paine, this journey proves that academic research can solve massive real-world challenges. Our mission remains empowering our students to dream big, creating high-tech jobs in Austin, and ensuring Texas leads the way in humanoid robotics to change the world.